Na et al., IEEE TSMC 52(8), 2022 · reproduction, diagnosis, extensions
Approximation-free active suspension, rebuilt and tested
The paper keeps a car body inside a shrinking performance envelope with a three-step, model-free controller on an electro-hydraulic rig. We rebuilt it on a calibrated hydraulic quarter car, checked the code five independent ways, and stress-tested the claims with control theory, fair comparators and road transients. Everything here is simulation.
Case-10 AFC IAE0.129m·s · paper 0.122
AFC command0.50 VRMS · paper ≈ 0.5 V
Hold-out error0.63test vs 0.22 train
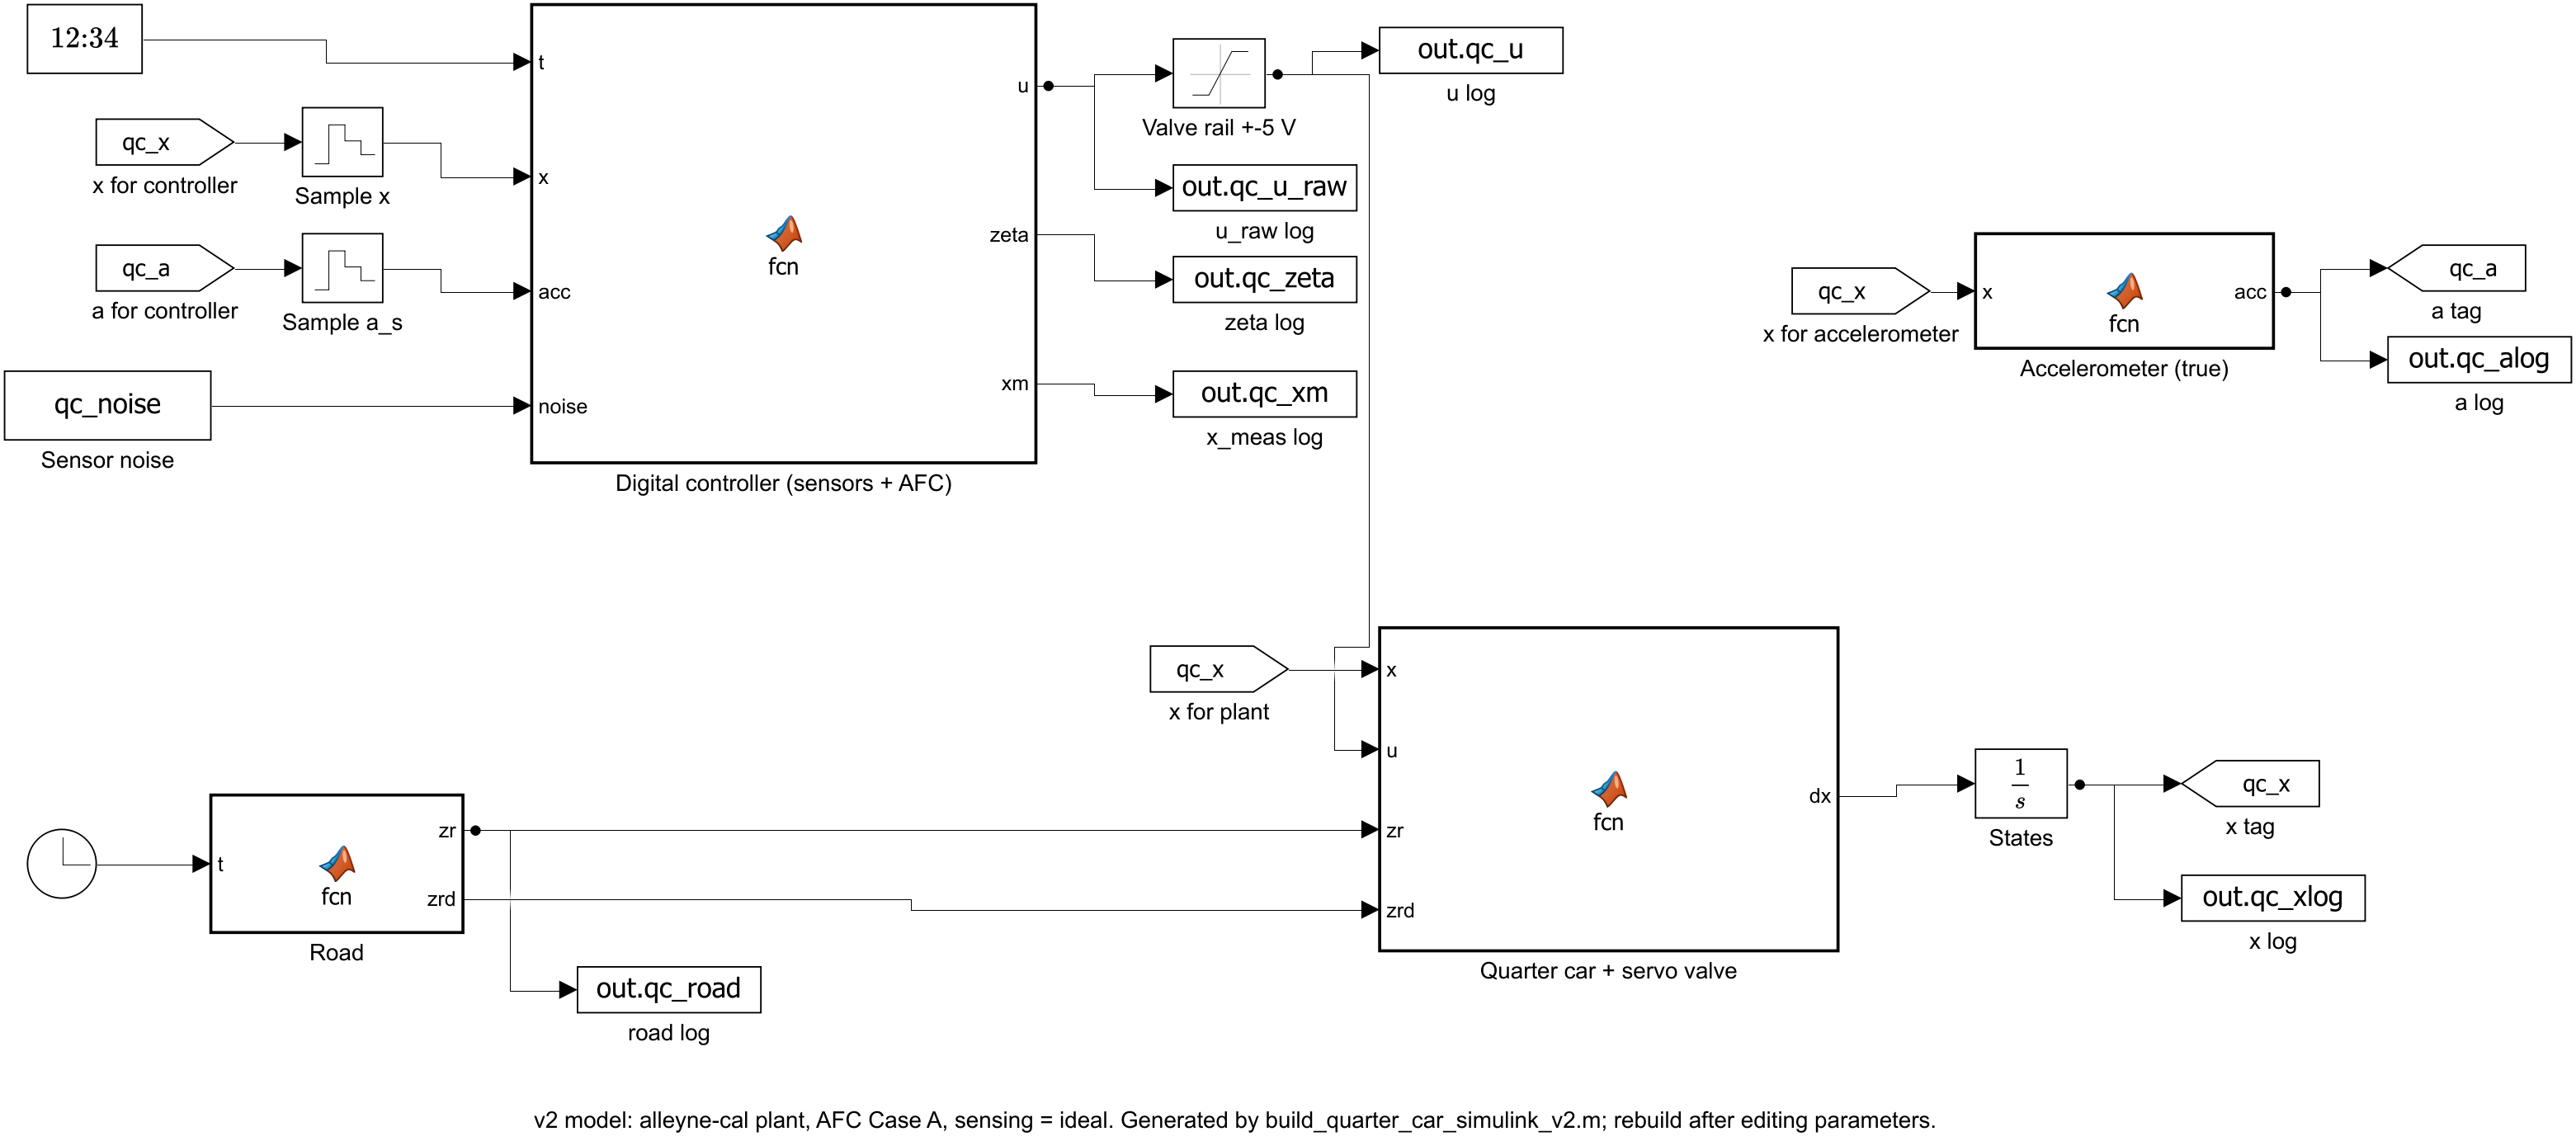
Simulink vs code4e-16 mmax body-position gap
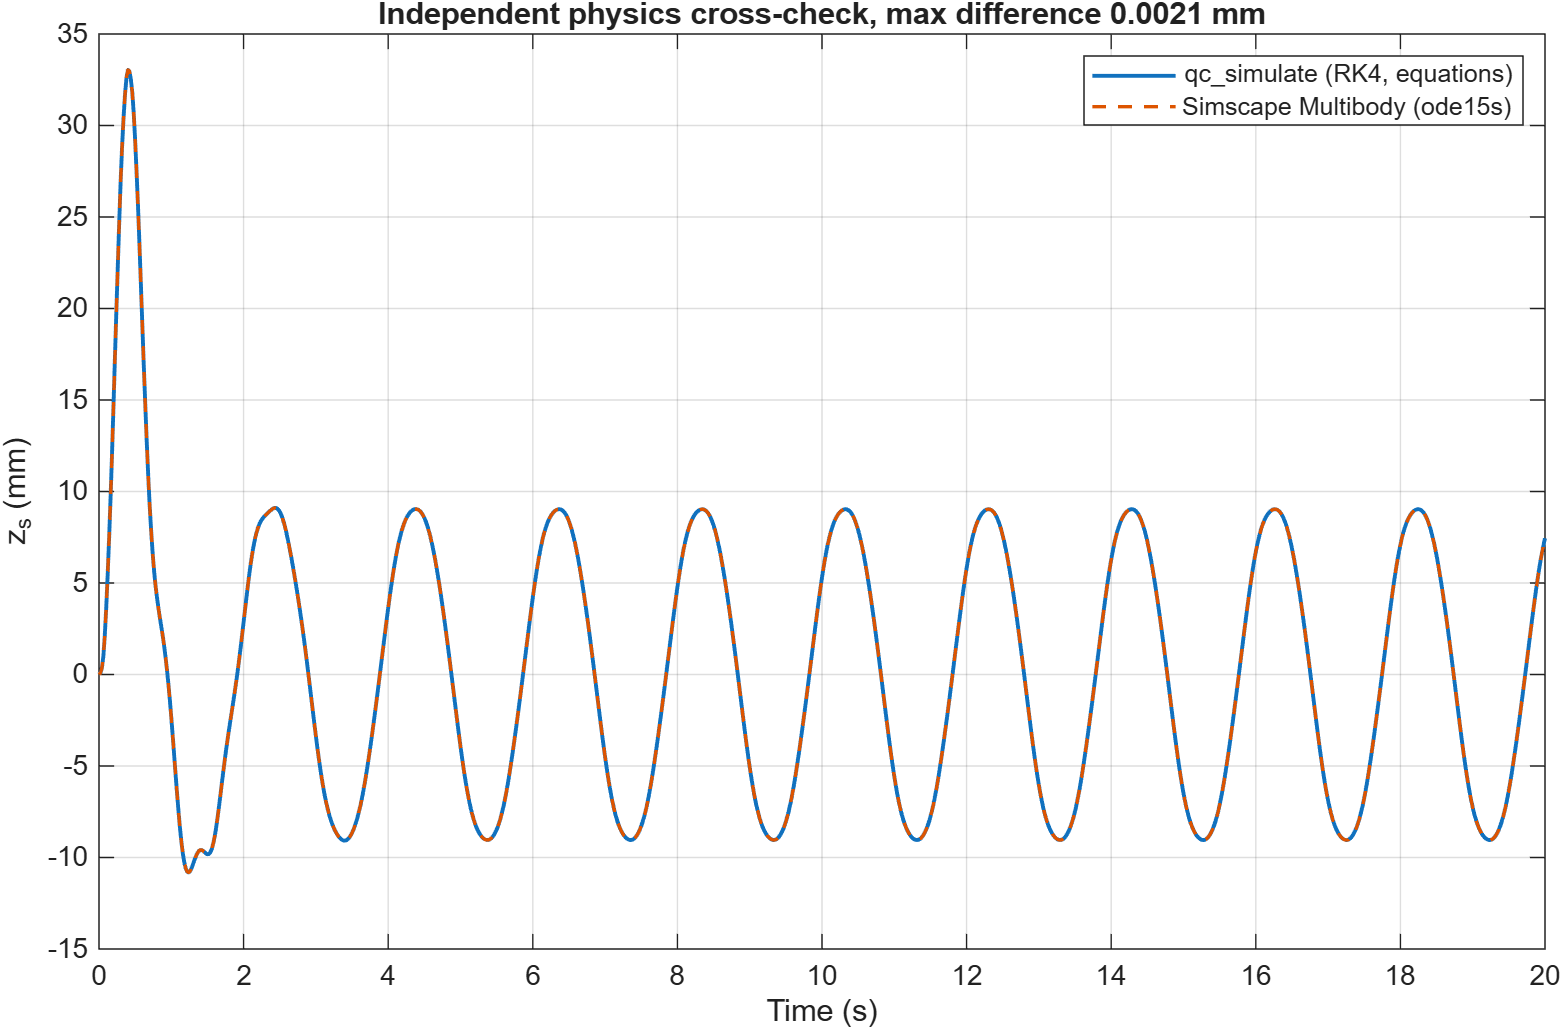
Multibody vs code2.1 µmmechanics from joints
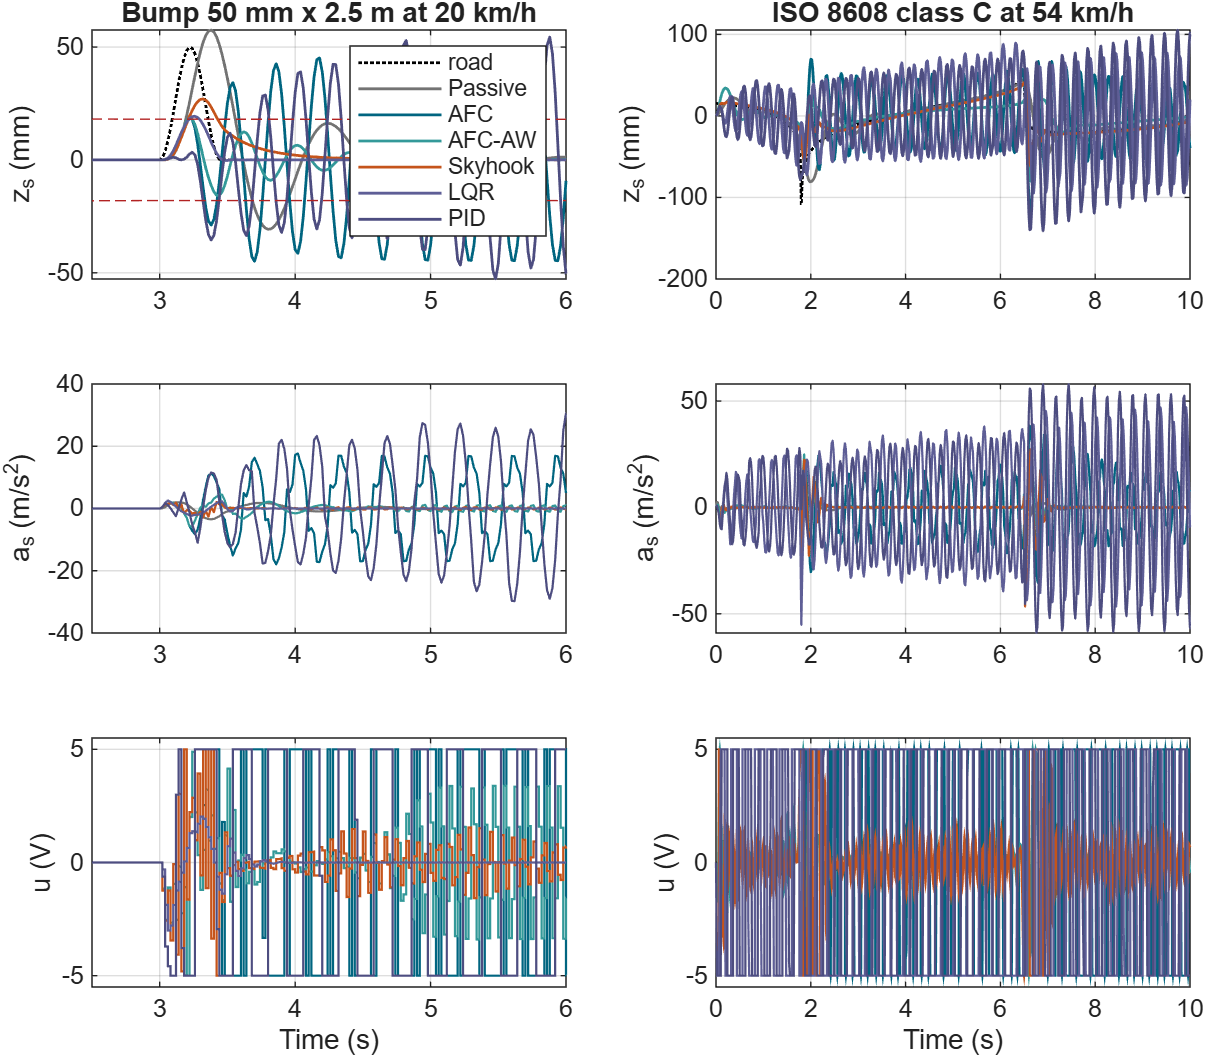
Bump tyre load, AFC-AW0.73×static · paper AFC 1.77×
Videos
All motion is simulated: the calibrated hydraulic quarter car driven over the same 50 mm bump, with vertical motion exaggerated four times so centimetre-level movement is visible.
What we found
Each number in the report is tagged as printed in the paper, read off a paper plot, calibrated, assumed, or simulated by us.
- The paper's AFC reproduces, on the right plant
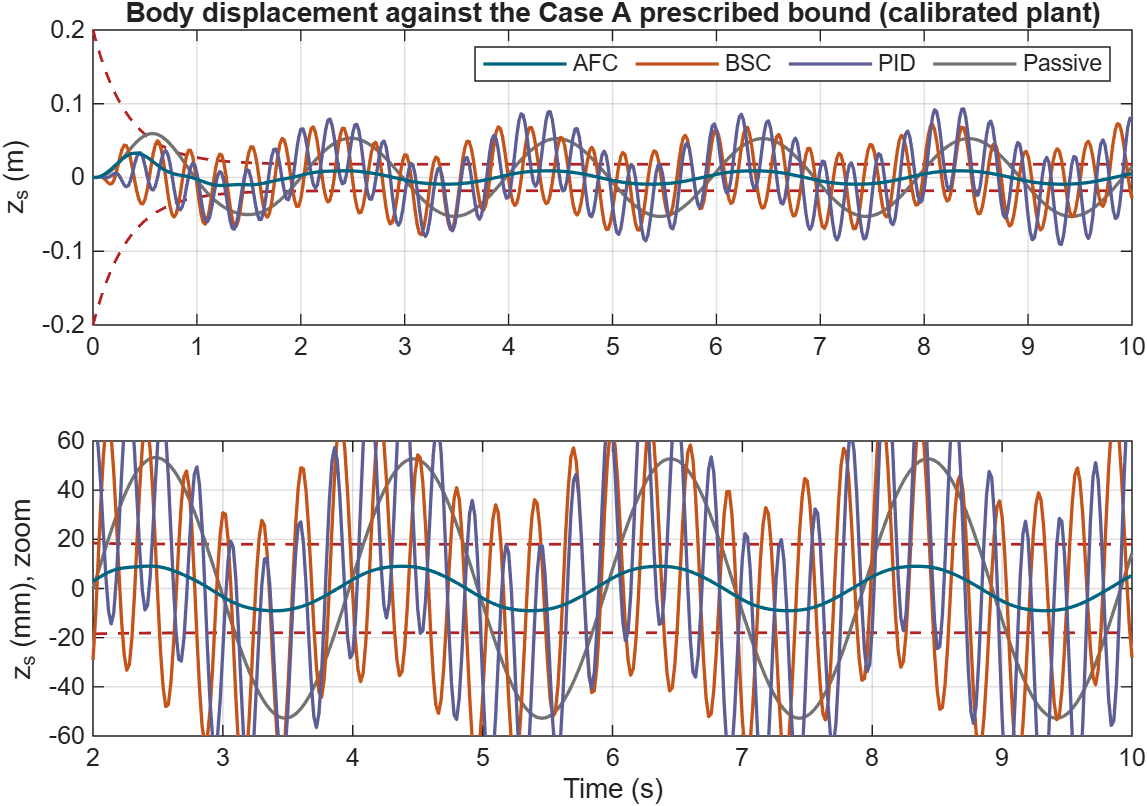
Two fitted factors (valve gain 5×10⁻⁴ m/V, 33 ms lumped lag) on a standard hydraulic quarter car give IAE 0.129, ITAE 1.20, ITSE 0.0088 against the paper's 0.122, 1.14, 0.0093, with the gains unchanged. BSC and PID saturate, as reported.
- But the rig can't be identified
The paper's slower-road gains fail a hold-out test: a joint fit across both gain sets has test error 0.63. Its pressure scaling, valve gain and lag are unpublished, and they decide the outcome.
- Our first model failed for a different reason
On the v1 plant the 50 Hz loop is locally unstable (spectral radius 1.02). Removing the ±5 V rail makes it worse, so saturation was a symptom, not the cause.
- The proof holds where its assumptions do
Lemma 1's bound is tight while the valve is unsaturated and fails exactly where it saturates. The continuous loop is stable, yet every zero-order-hold implementation we tried (1–20 ms) is locally unstable through an 88 Hz hydraulic mode.
- Near zero error, AFC is a skyhook spring
About 63 kN/m with little damping: strong at the road frequency, worse than passive in the 4–8 Hz comfort band. At equal effort, LQR and skyhook match or beat it.
- One extra state fixes the bump
Letting the envelope widen while the valve saturates removes rail-to-rail switching in the quarter car and the half car, and leaves Case 10 untouched.
Figures
From the MATLAB R2026a run; every figure is regenerated by run_phase1–run_phase3b.
Five implementations, one answer
Before trusting any number, the same equations were rebuilt independently and compared.
| Implementation | What it adds | Agreement with the MATLAB library |
|---|---|---|
| Simulink v2 | block diagram, 50 Hz digital controller, sensor noise path | 4×10⁻¹⁶ m |
| Simscape Multibody | mechanics from prismatic joints, not our equations | 2.1 µm |
| C on Cortex-M4 (QEMU) | instruction counts for the paper's timing claim | 10 digits |
| Browser lab (this site) | interactive teaching tool | IAE to 4 digits |
| GNU Octave 8.4 | runs without a MATLAB licence | same digits* |
* except a few runs riding the ±5 V rail, where the locally unstable loop amplifies rounding differences.